PROJECT / Completed
Smart-Vehicle Communication & Testing
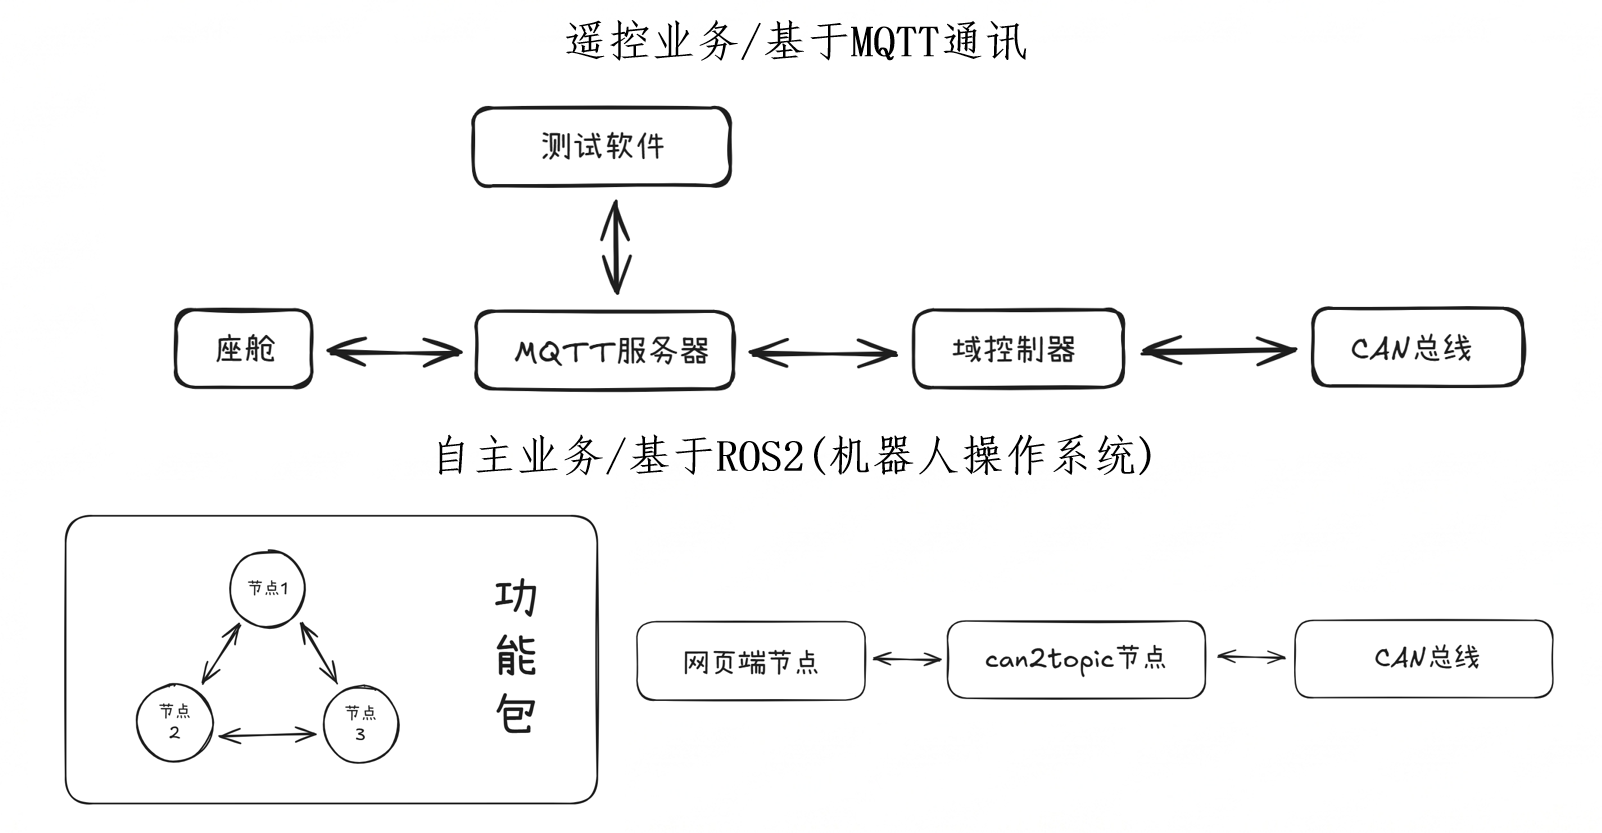
ROS 2 communication relay · tested and deployed
Industry internship work: bidirectional MQTT testing, vehicle-model adaptation, and a ROS 2 communication relay.
Delivered software
Message processing and forwarding between web and CAN interfaces
Debugging tool
MQTT connection, simulated sending, subscriptions, and logs
Results
During an approximately four-month internship, delivered a bidirectional MQTT test simulator and developed a ROS 2 relay between web and CAN interfaces, tested and deployed in the field.
My contribution
- Built a Python/Tkinter simulator with connection status, message logs, and bidirectional testing to identify basic communication issues before field debugging.
- Developed a ROS 2 message-processing and forwarding node and participated in vehicle tests.
- Adapted MQTT software for different vehicle models and traced defects through code and logs.
Engineering lessons
Clear interfaces, shared knowledge of field conditions, and reproducible logs make both debugging and collaboration more effective.